Research

Research in robotics and machine autonomy.

Selected work

03 projects
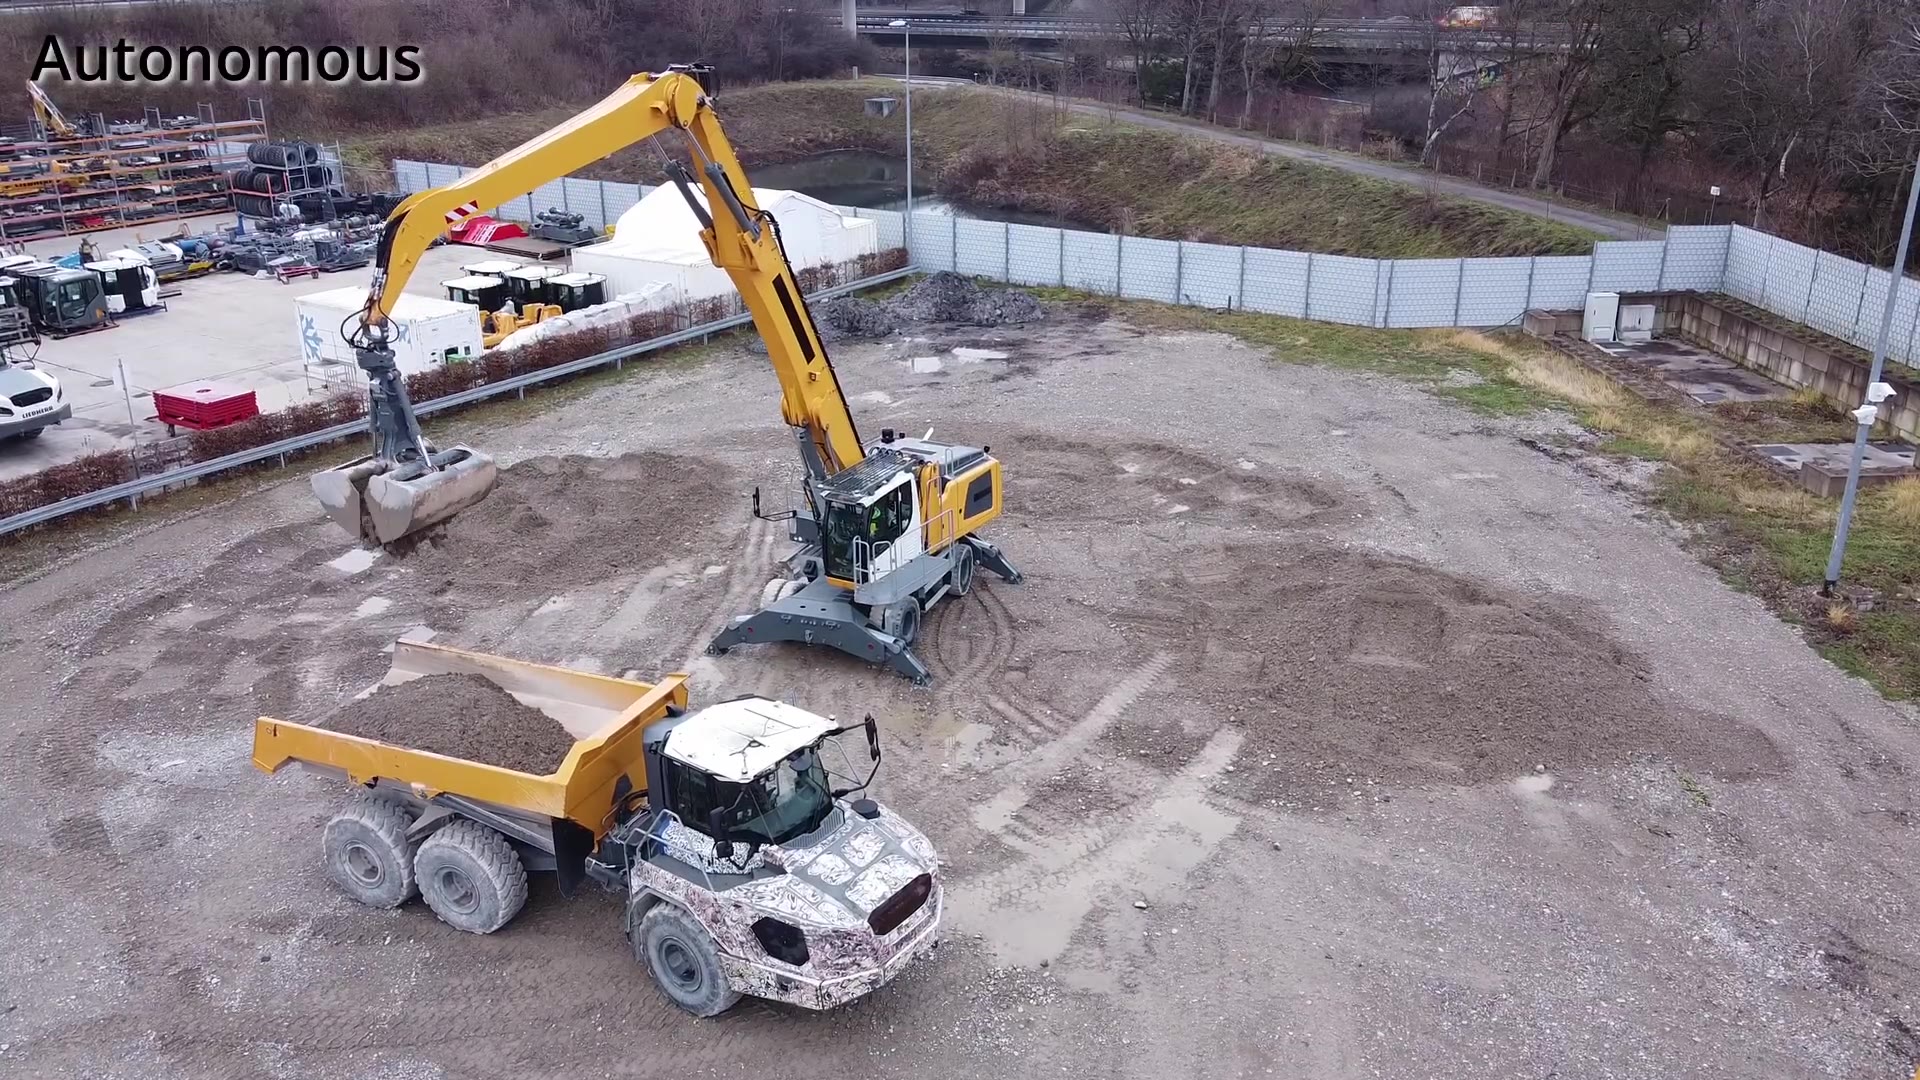
An overhead view of a hydraulic material handler picking up material and unloading it into a truck.

Paper & video

Material handling

Perception, planning, and learned control coordinate bulk material transfer on a 40-ton hydraulic machine.

This research combines a learned grasp-location planner, obstacle-aware motion planning, and learned hydraulic controllers to pick up, transport, and unload material with a freely swinging gripper.
View project Read paper
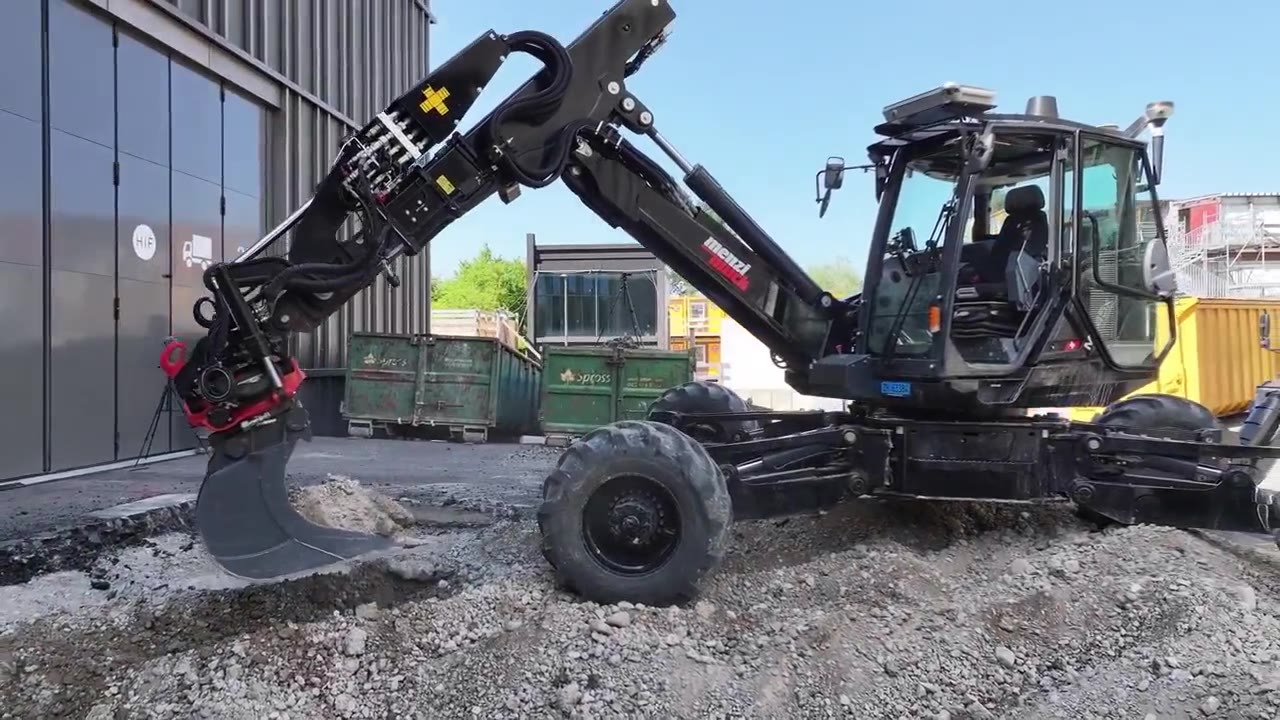
A close view of an excavator bucket engaging the ground and lifting material.

Field video

Excavation

A hydraulic excavator engages the ground and lifts material in a field research demonstration.

Excavation brings the machine into sustained contact with the ground. This field clip shows bucket engagement through lift, one of the material-interaction tasks that motivates our work on reusable manipulation skills.

View project
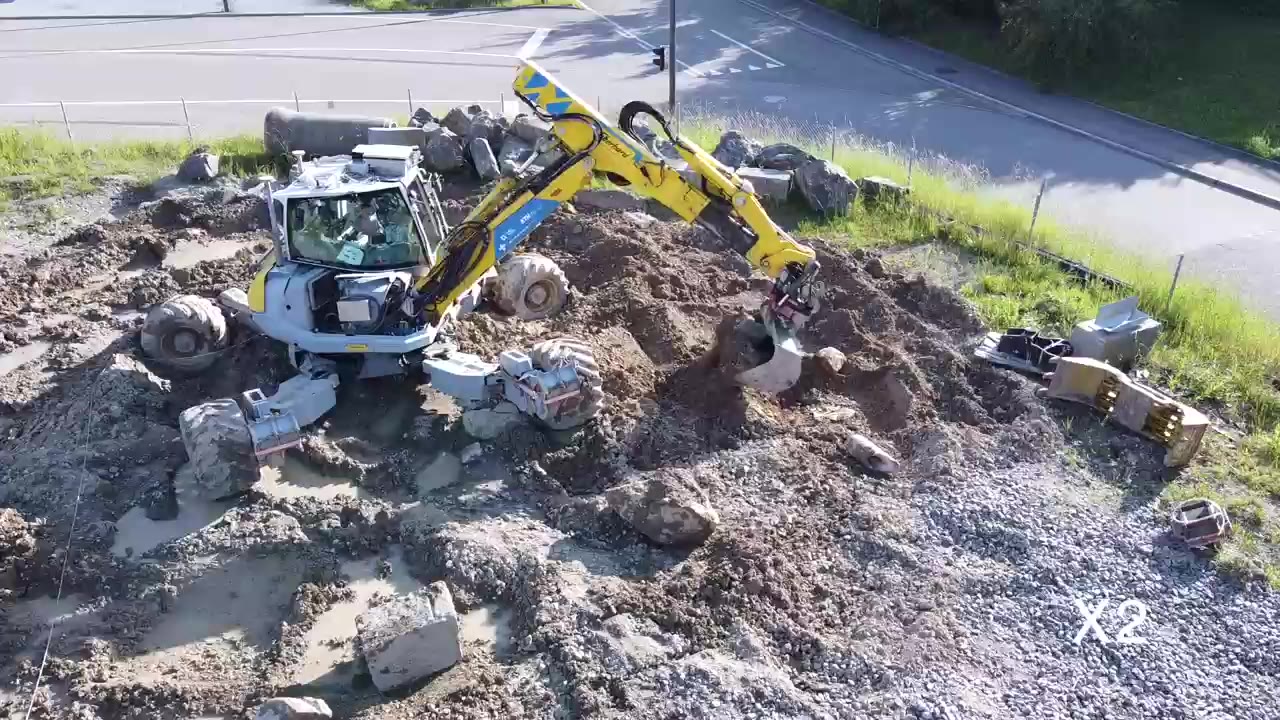
An overhead view of an excavator bucket contacting and lifting a boulder from rocky ground, shown at 2× speed in the source film.

Paper & video

Boulder extraction

A policy trained in simulation uses sparse LiDAR and machine feedback to lift boulders with a standard bucket.

Tested on a 12-ton excavator, the learned policy coordinates the arm and bucket while adapting its digging motion to different soil resistance. It uses sparse LiDAR and machine feedback; an operator initializes the target segmentation.

View project Read paper